 CIRP
Research / Imaging and Perception Systems for Robotics / Perception for robotic manipulation
3PT and 3PTv2 for Robotic Manipulation
With Google Intrinsic, we developed the 3D-Object Perception Transformer (3PT) to estimate a part’s position and orientation from its 3D model and a color image. Its successor, 3PTv2, estimates poses for parts it never saw during training. In this zero-shot setting, 3PTv2 substantially reduces inference time and improves pose accuracy.
Learn more on the Intrinsic website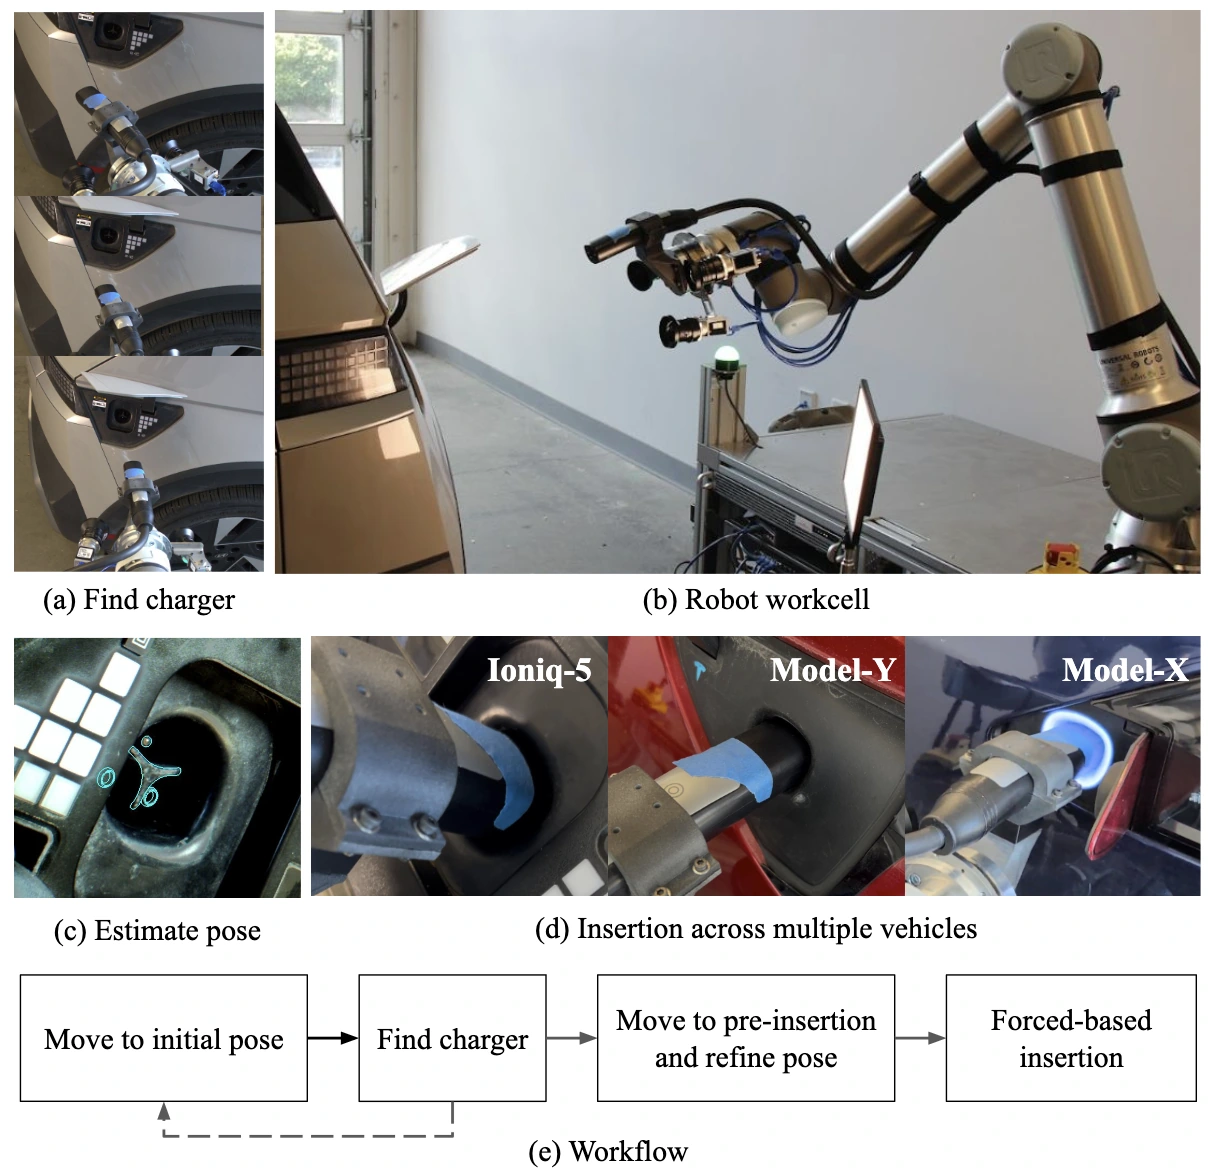
Project team
CIRP researchers
Agastya Kalra · Huaijin Chen