 CIRP
Research / Imaging and Perception Systems for Robotics / Marine robotics and perception
FishPod: Underwater Stereo Vision for Fish Measurement
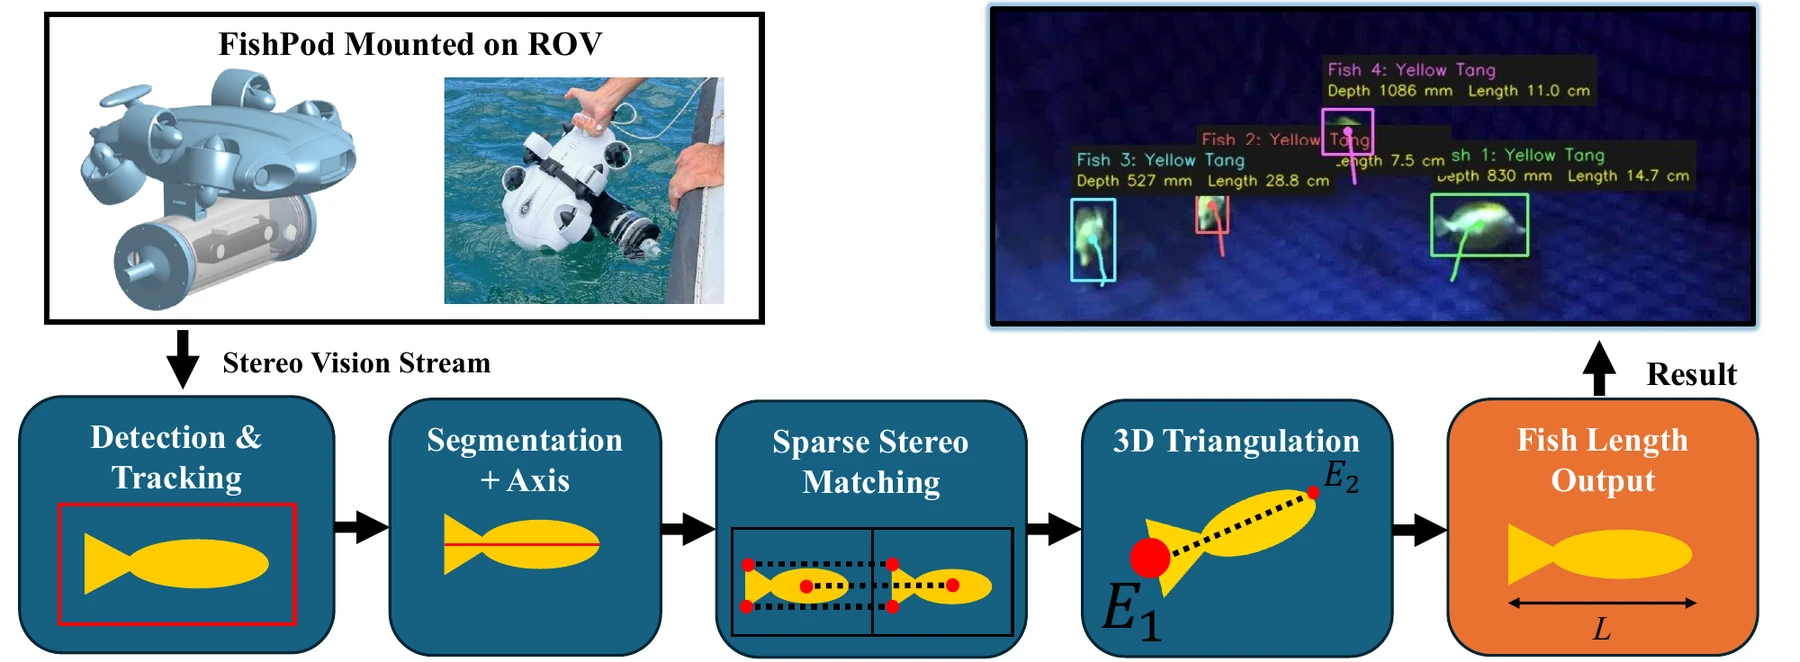
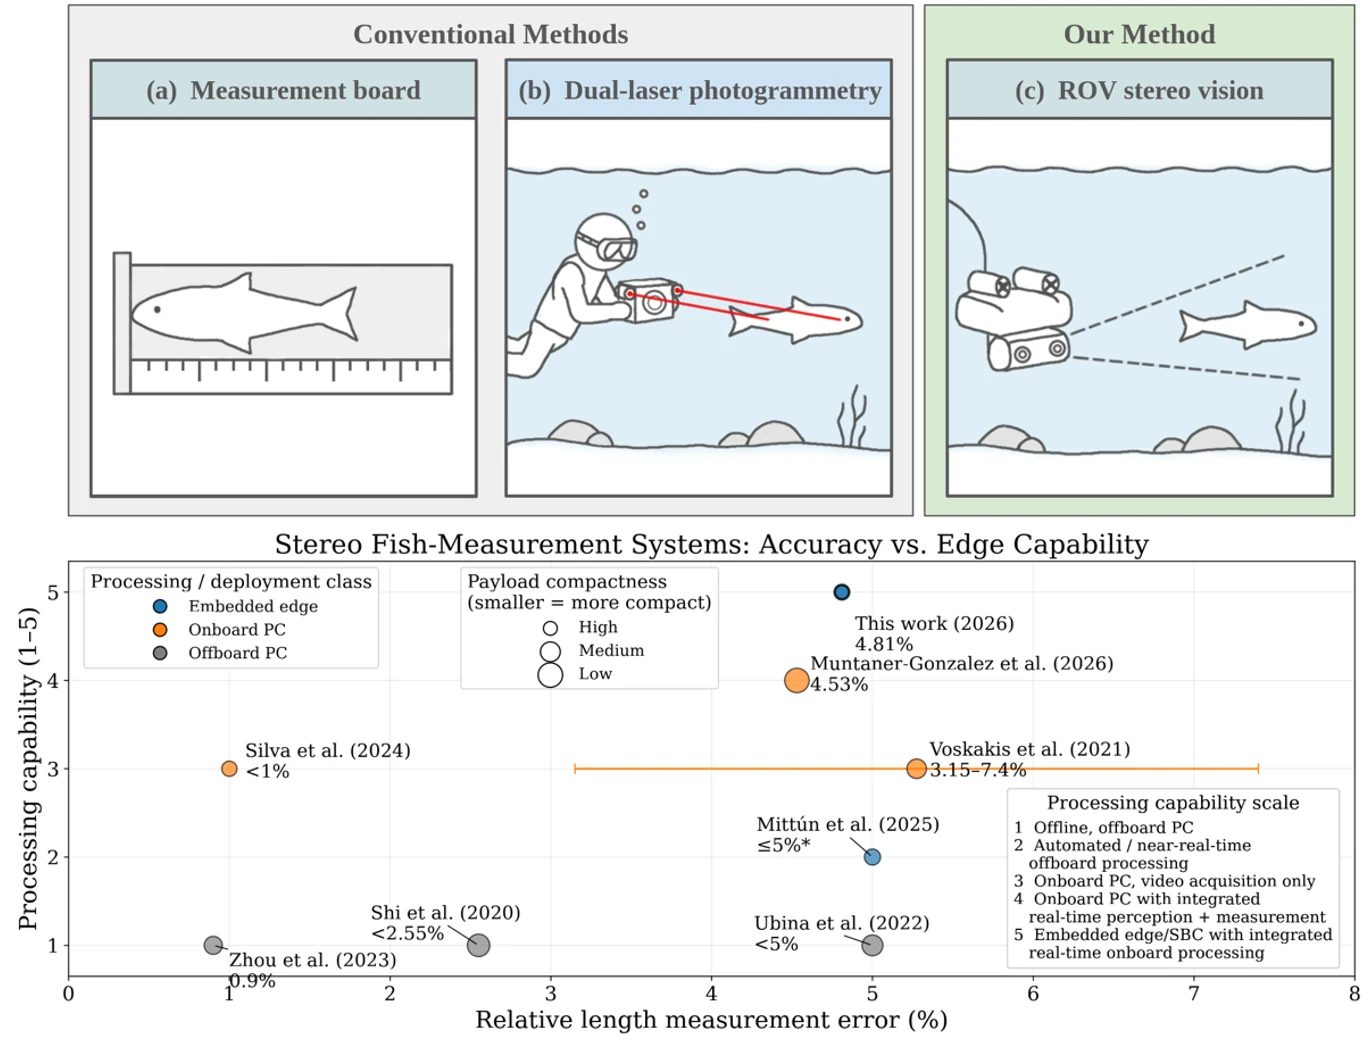
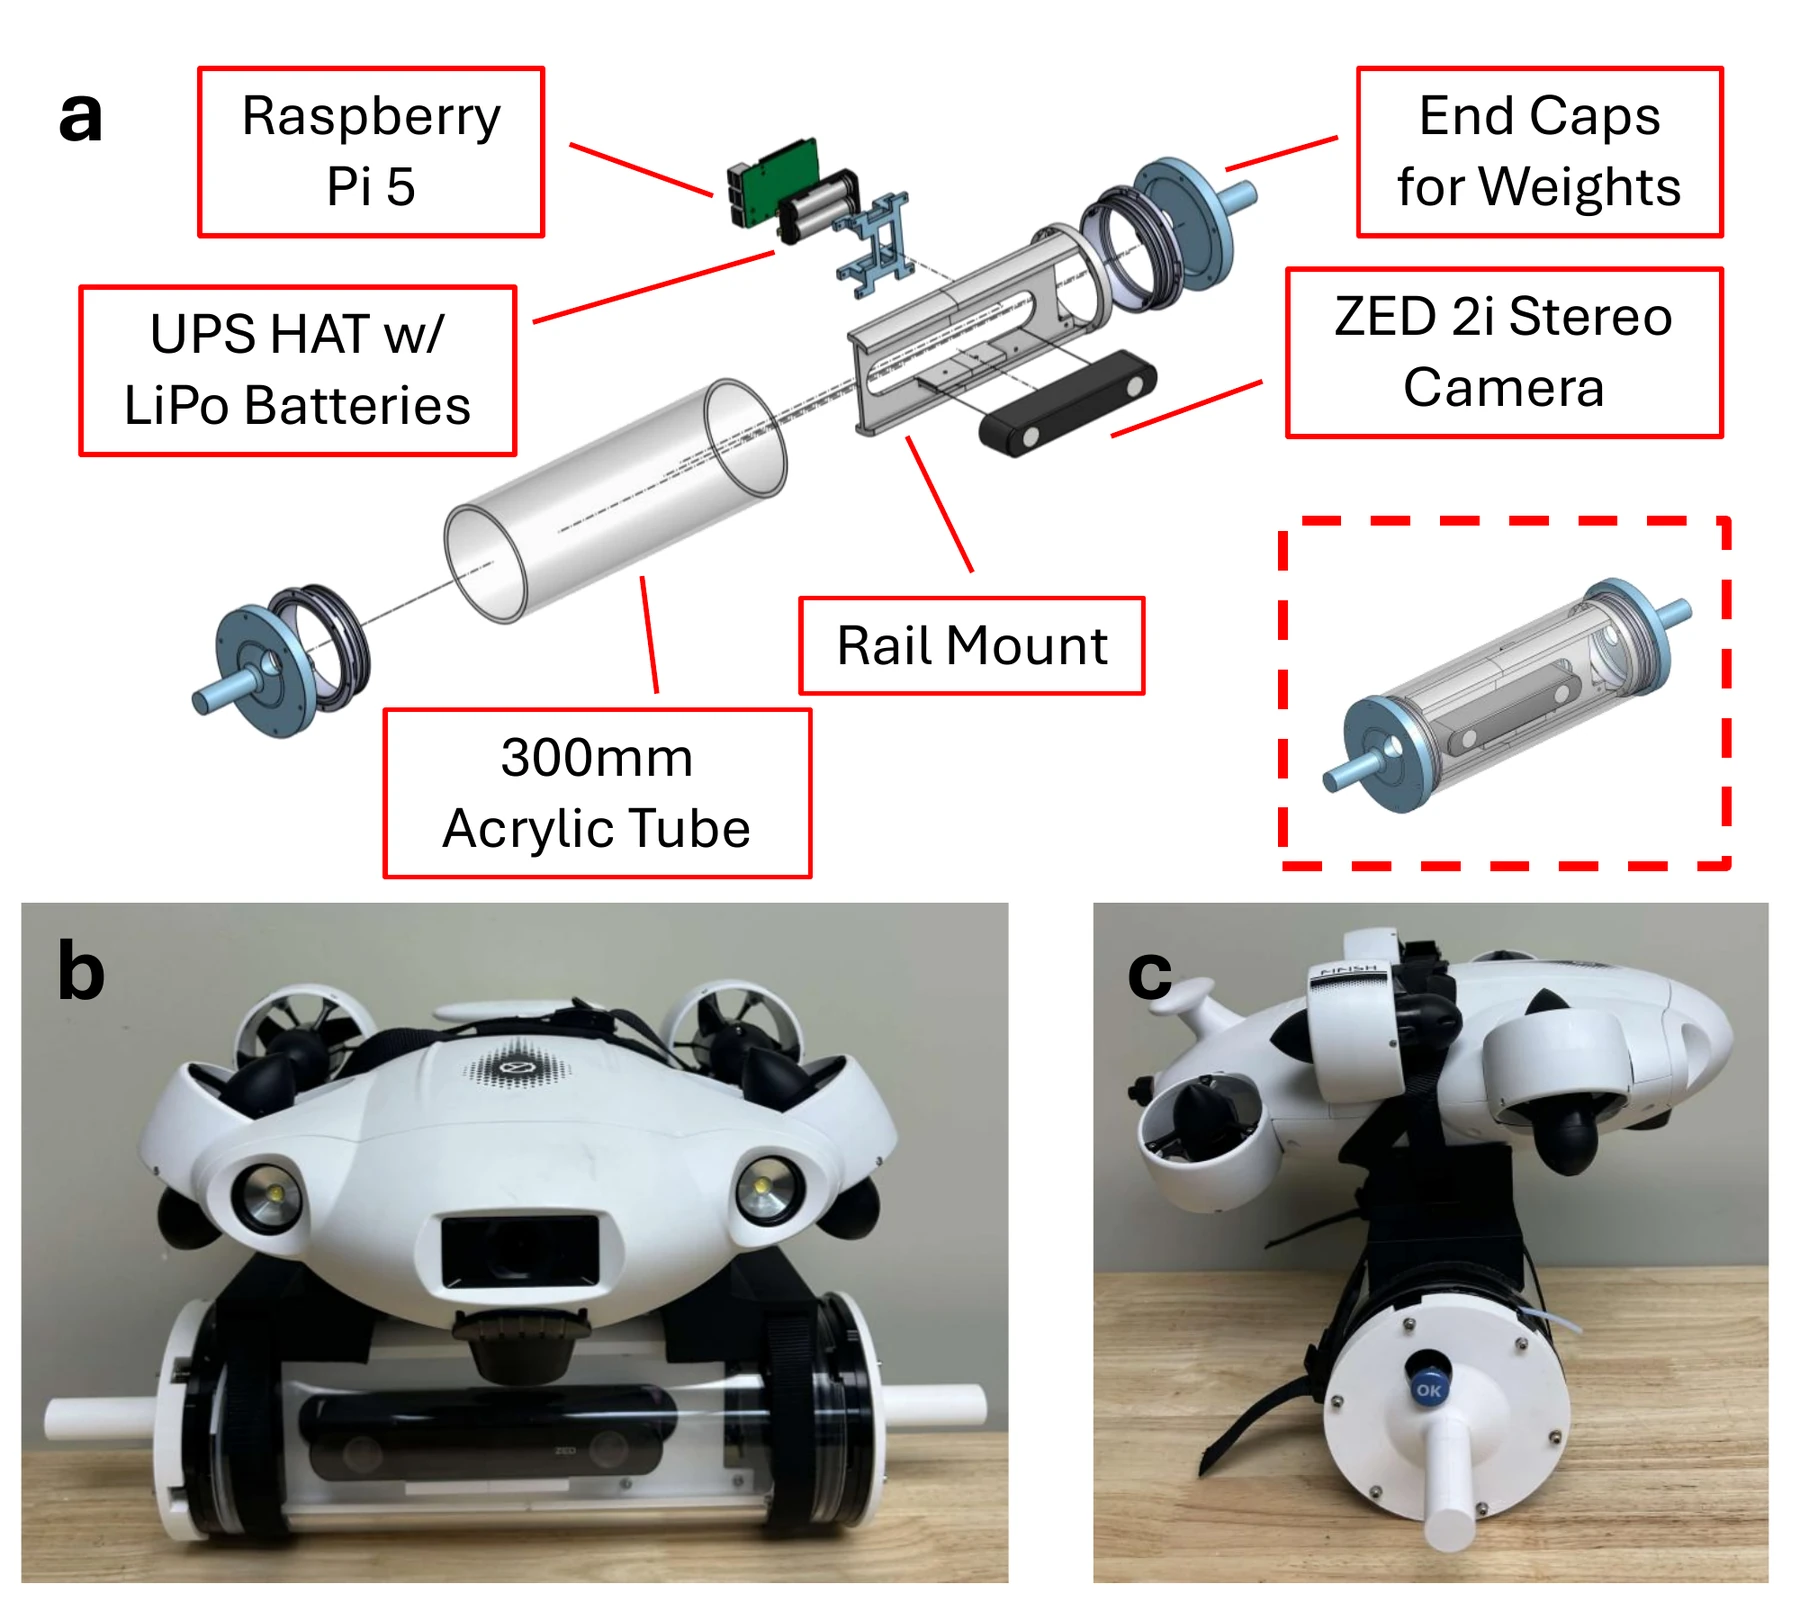
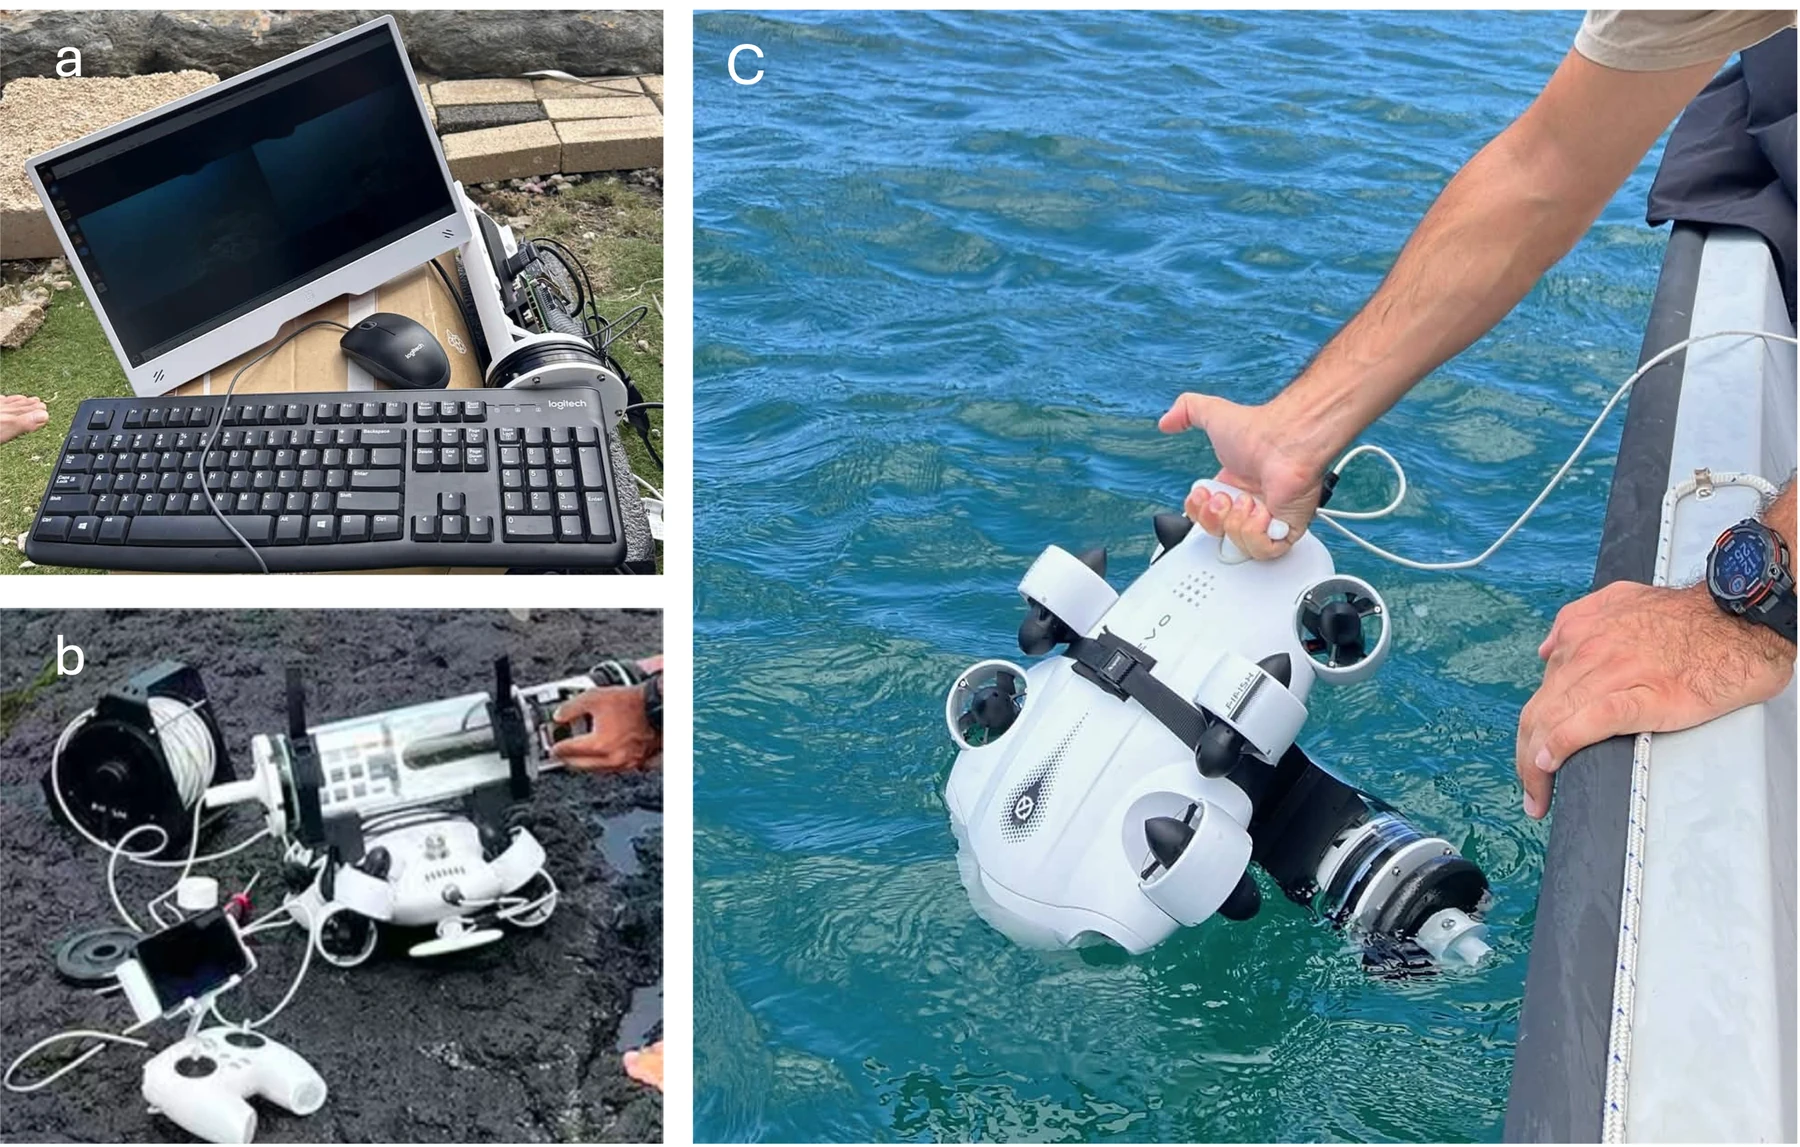
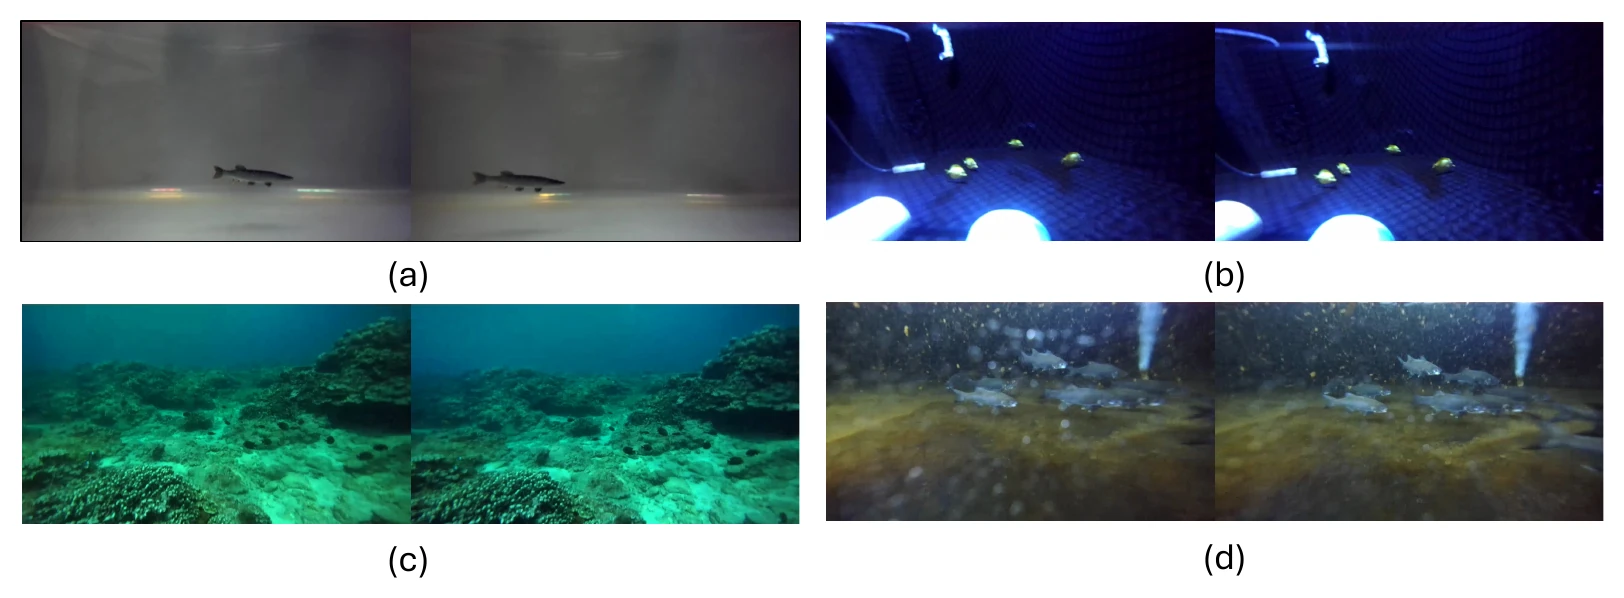
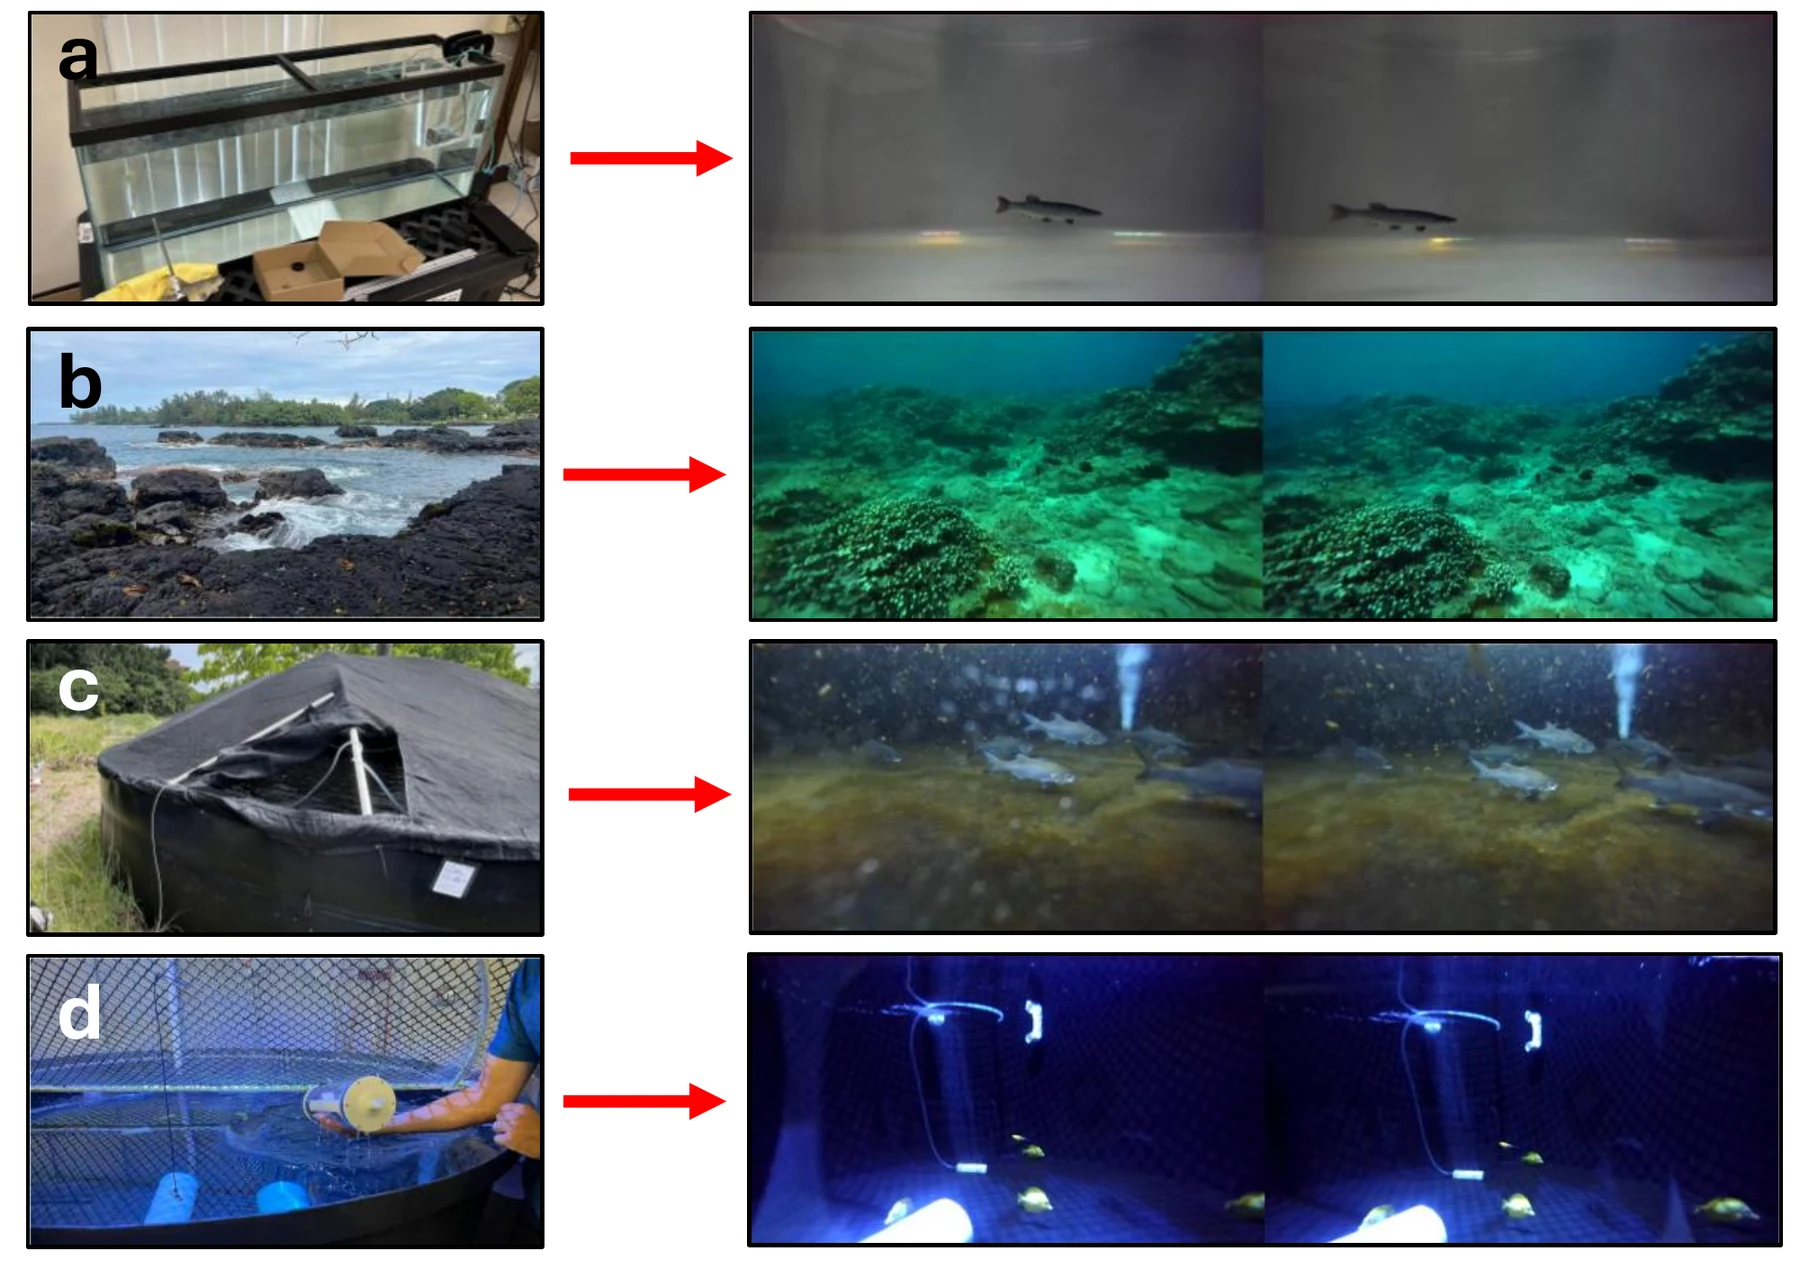
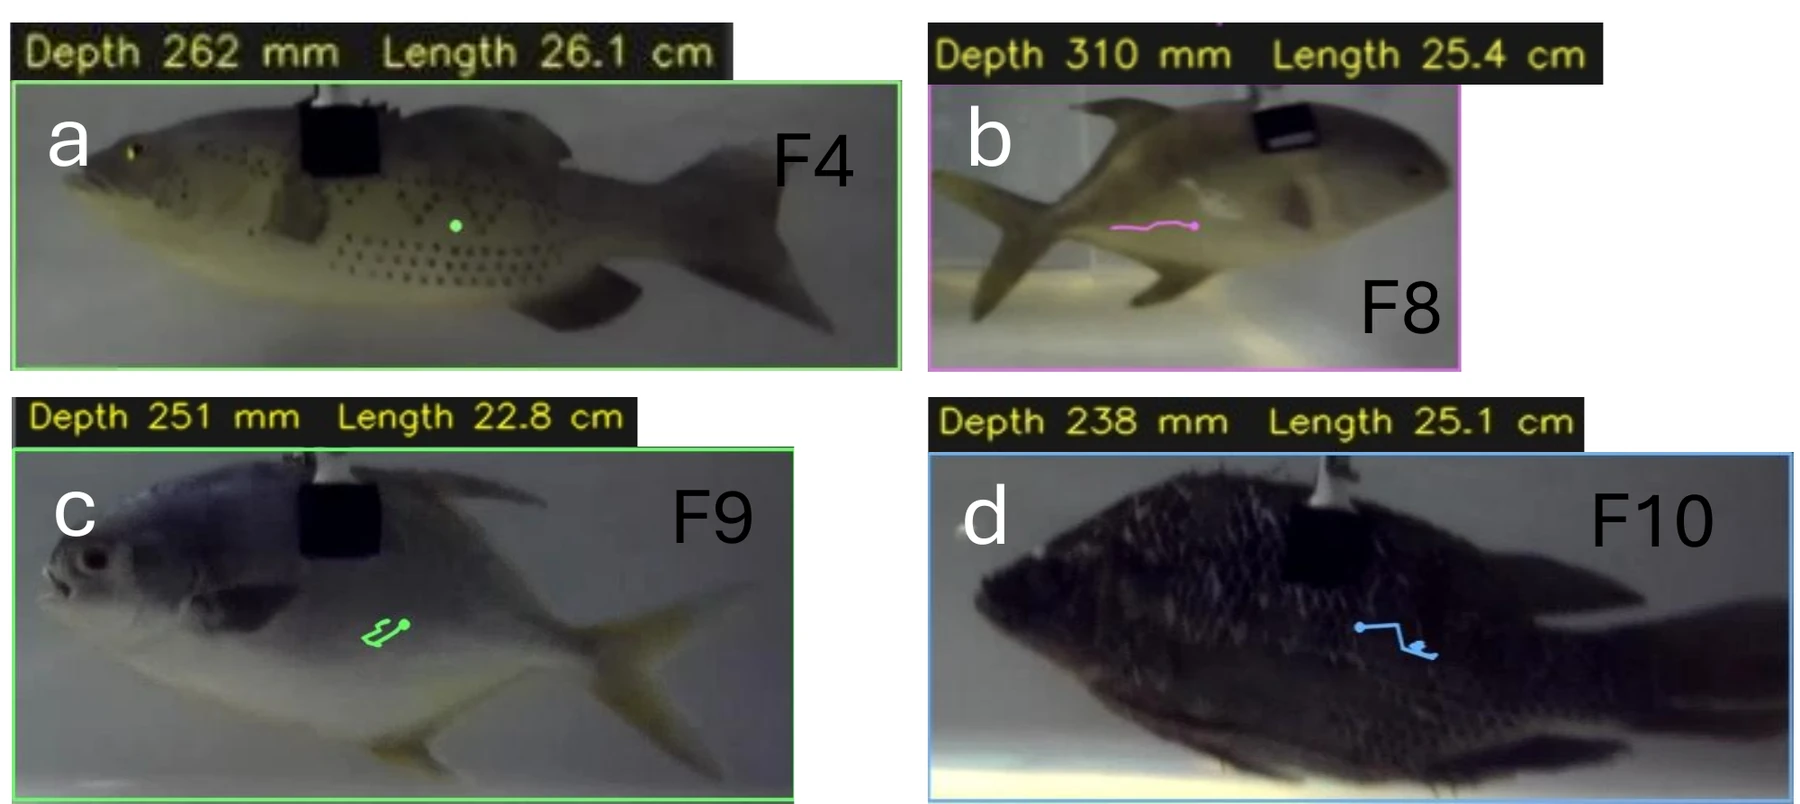
FishPod uses a stereo camera mounted on a remotely operated underwater vehicle to estimate fish length from paired video frames.
Project overview
The system detects and tracks fish, segments their outlines, and matches points along their body axes between the two camera views. Stereo triangulation locates the endpoints in 3D so the system can estimate body length.
Hardware, deployment and measurements
Project team
Principal investigator
Huaijin Chen
Contributors
Feimei Chen · Riki MacMillan · Munir Zarea