 CIRP
Research / Imaging and Perception Systems for Robotics / Agricultural robotics
Autonomous Coconut Rhinoceros Beetle Infestation Management
A palm-climbing robot designed to inspect trees and treat coconut rhinoceros beetle infestations.
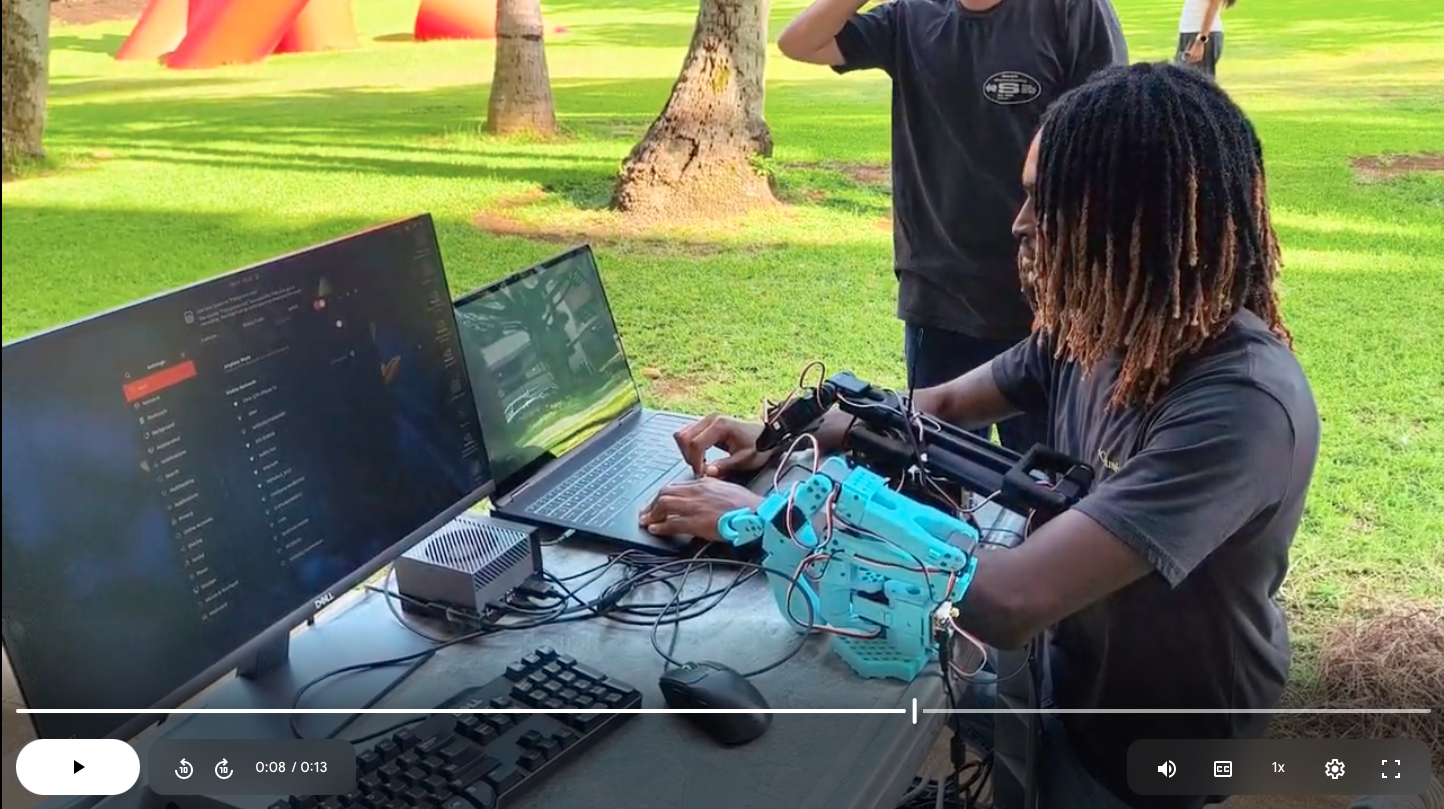
Project overview
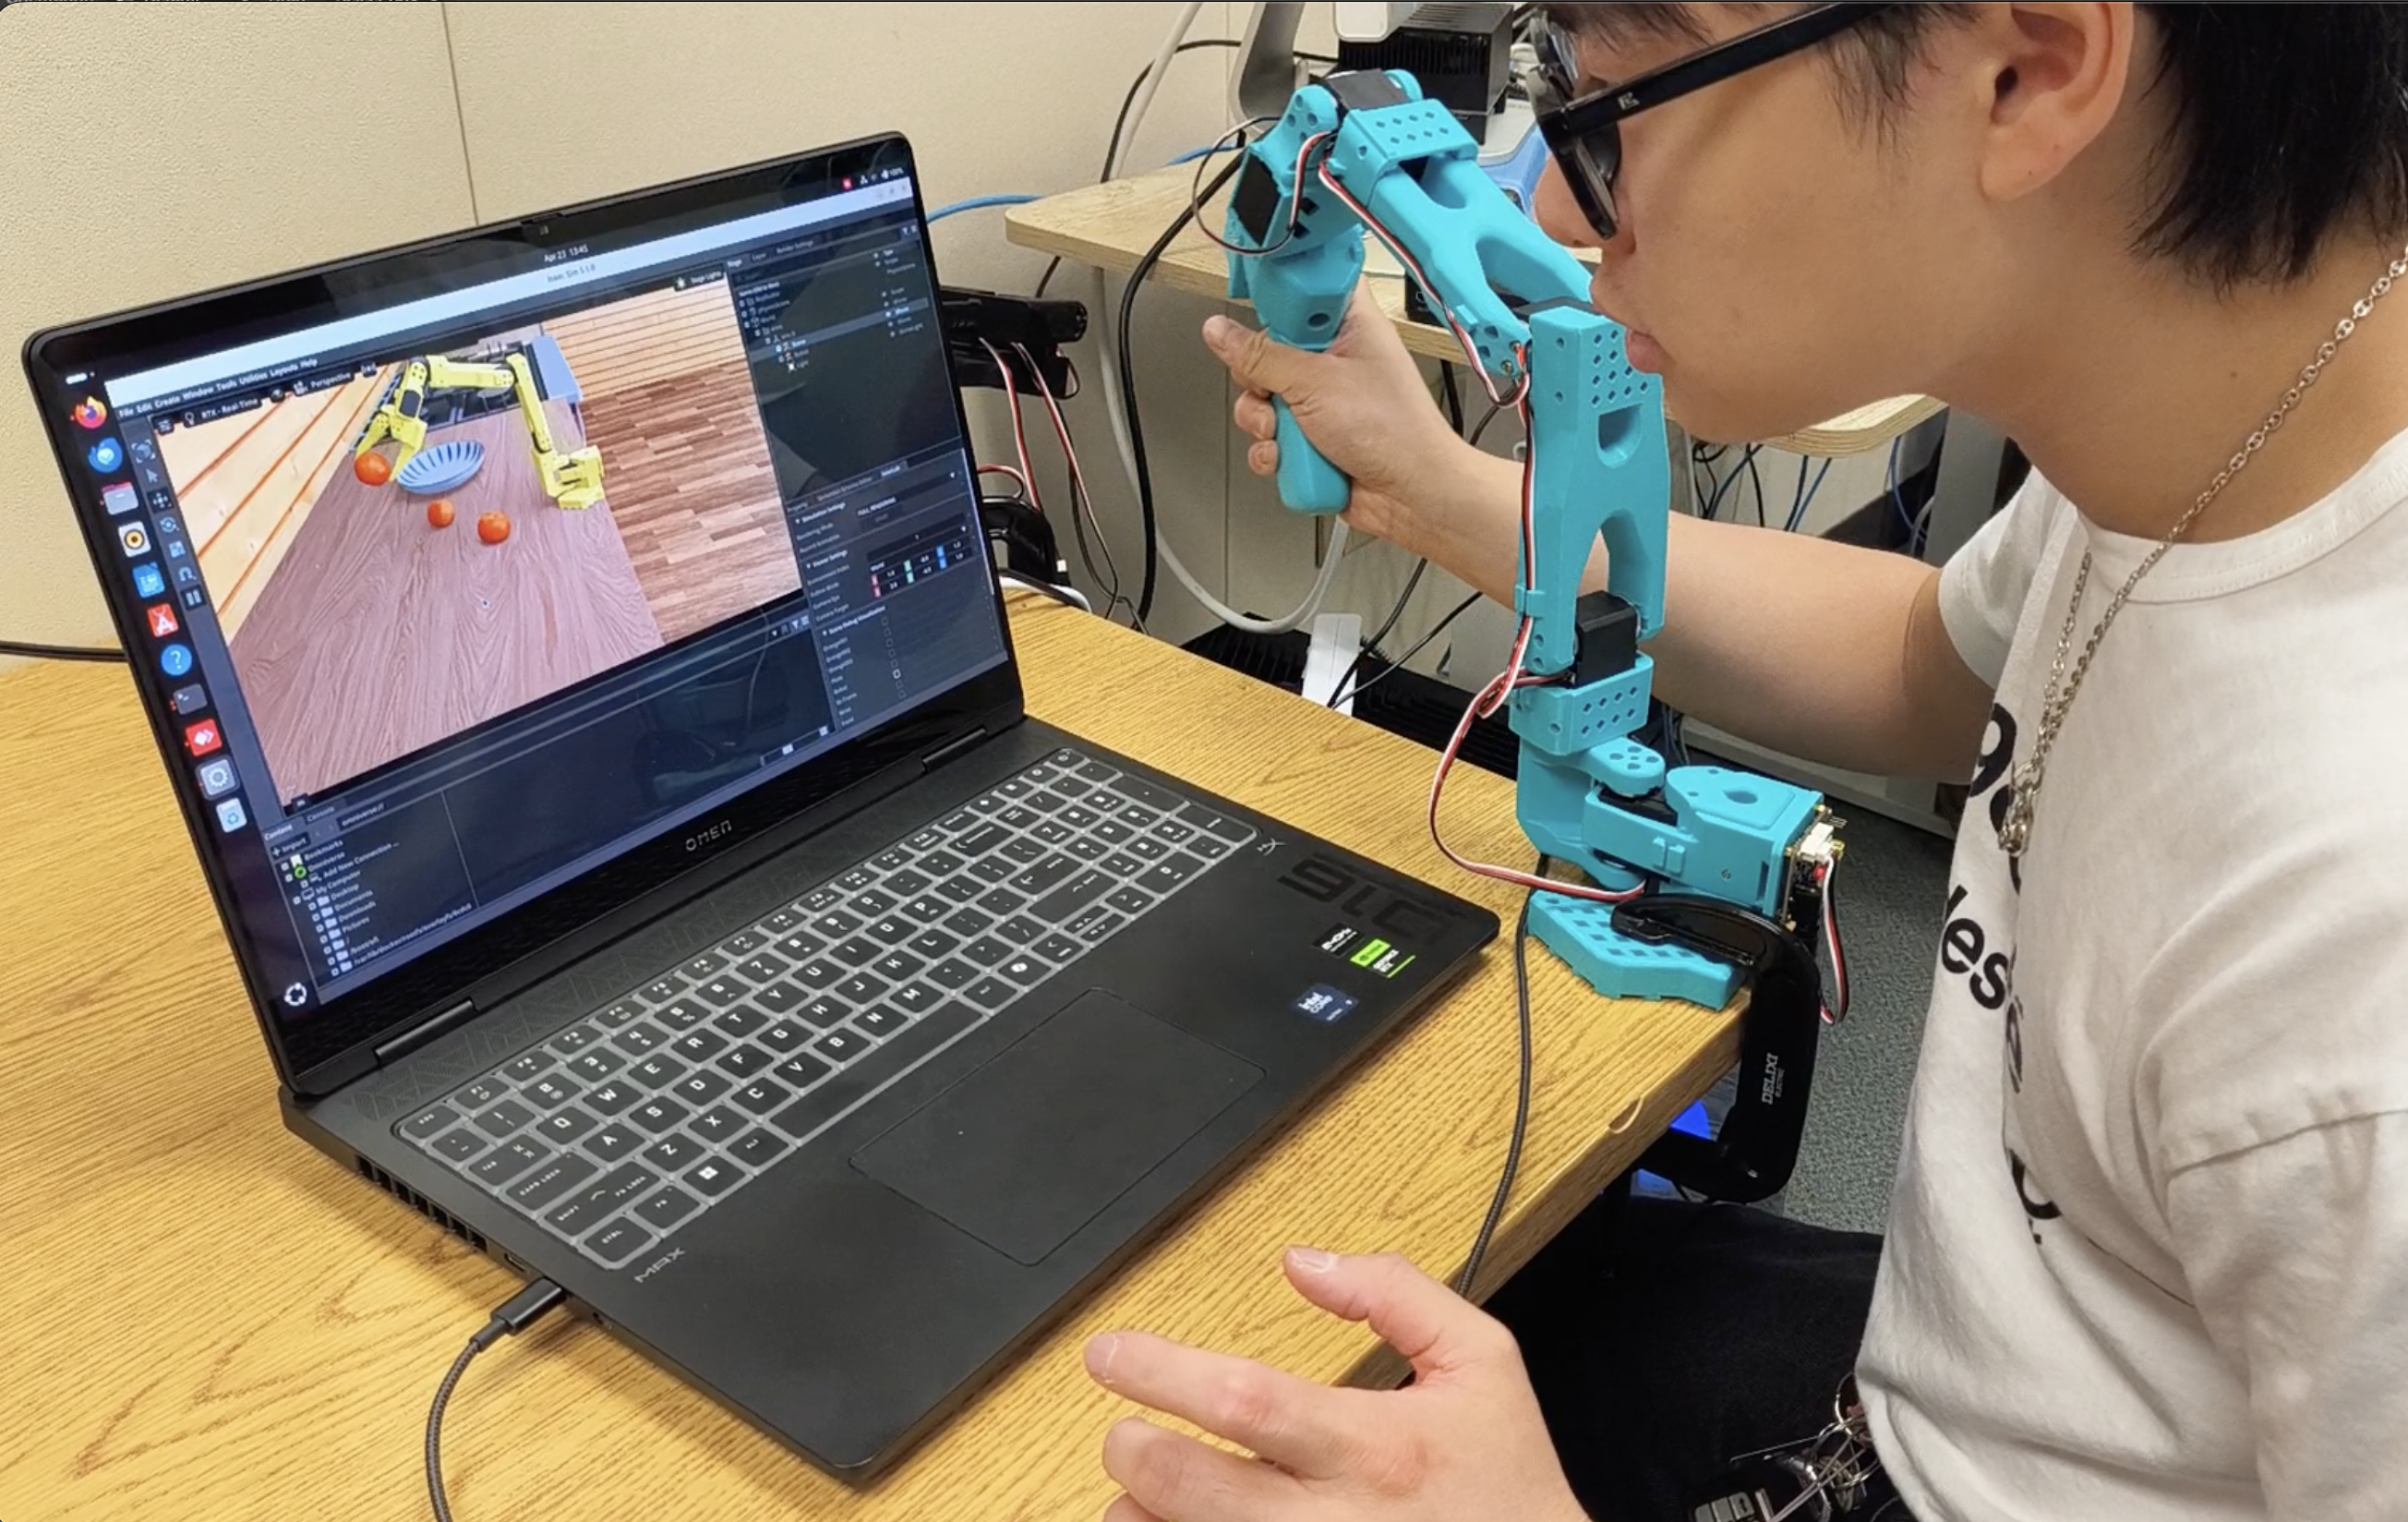
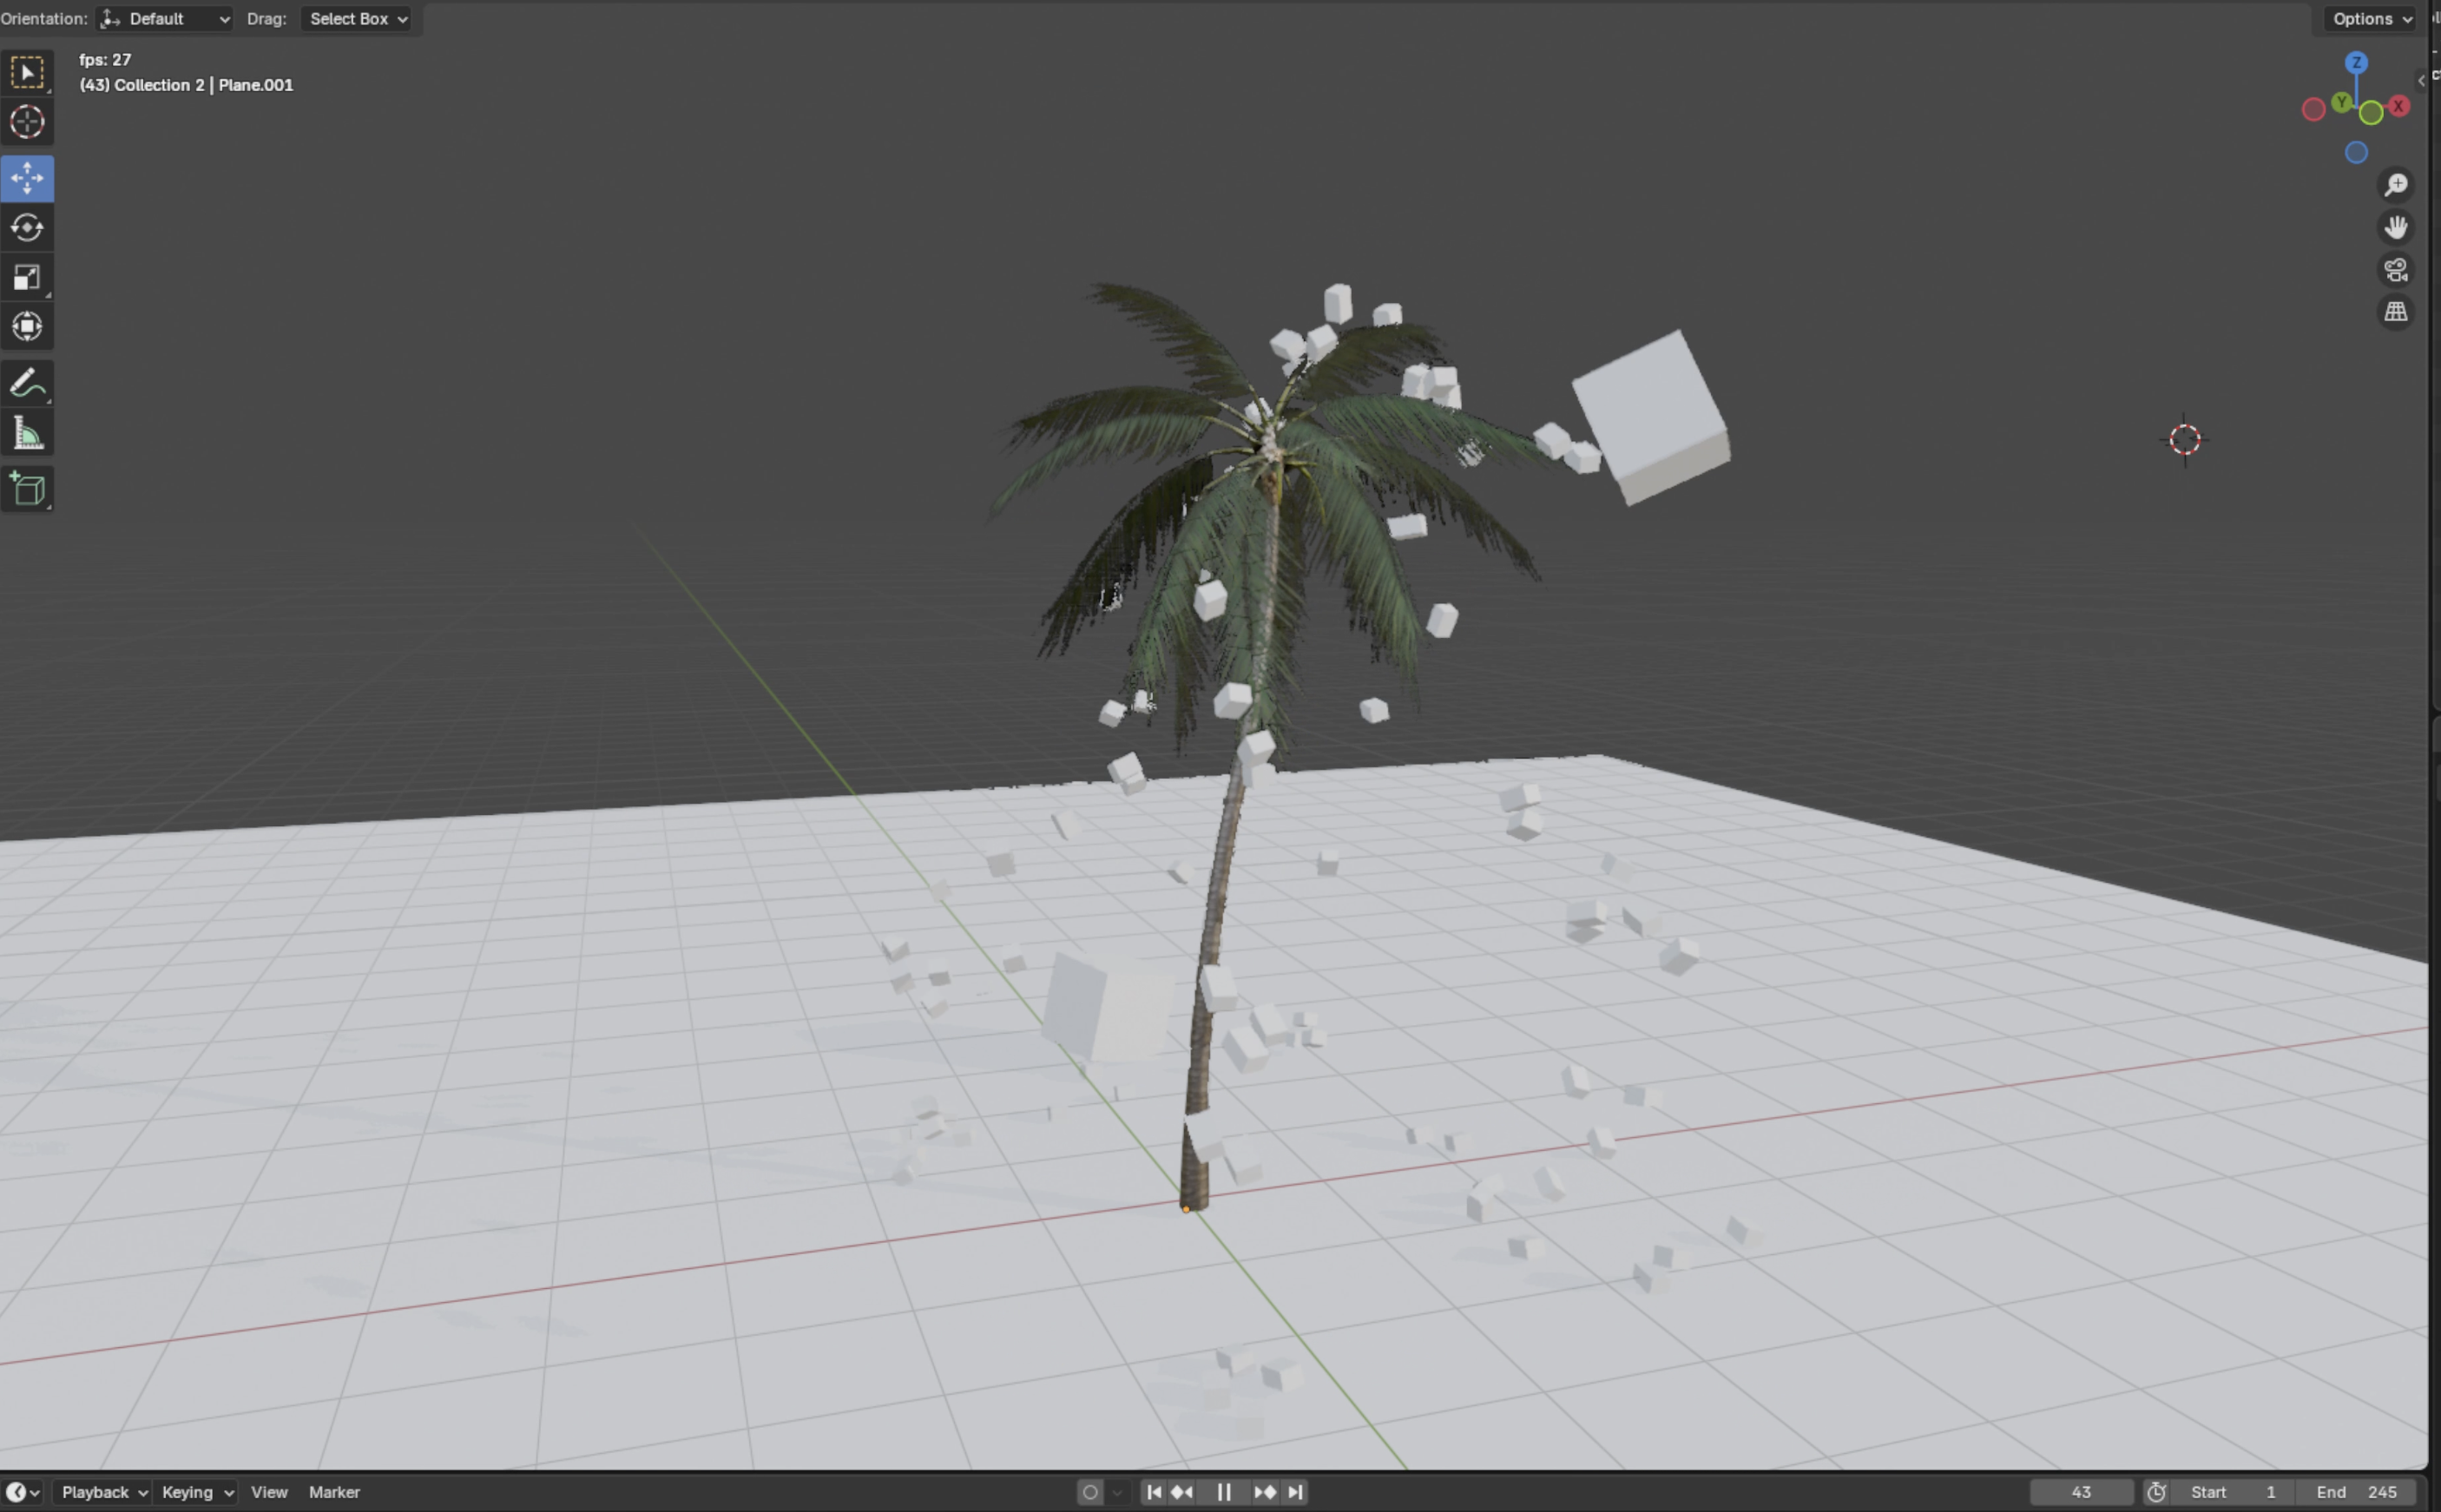
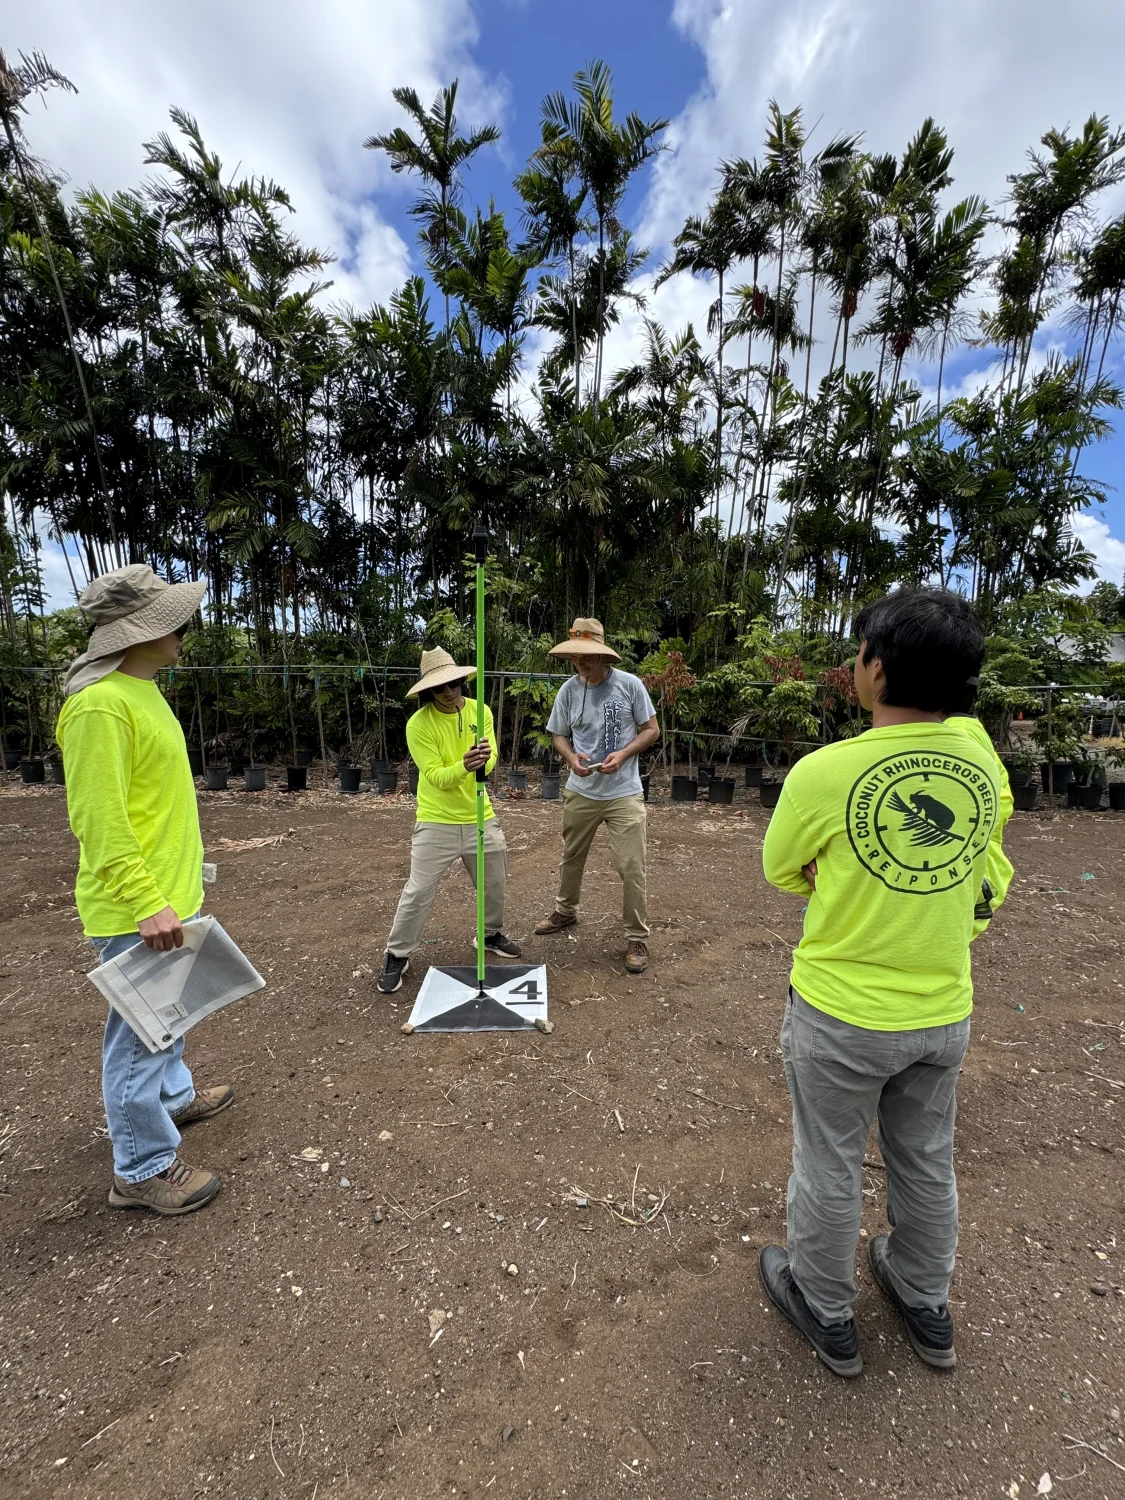
The team is developing a mechanism to climb palms and an end effector to apply pesticides and trim flowers. They use simulation and teleoperated trials to study how the arm interacts with a tree before hardware tests. We thank NVIDIA for supporting this work on palm health for the 2026 Farm Robotics Challenge.
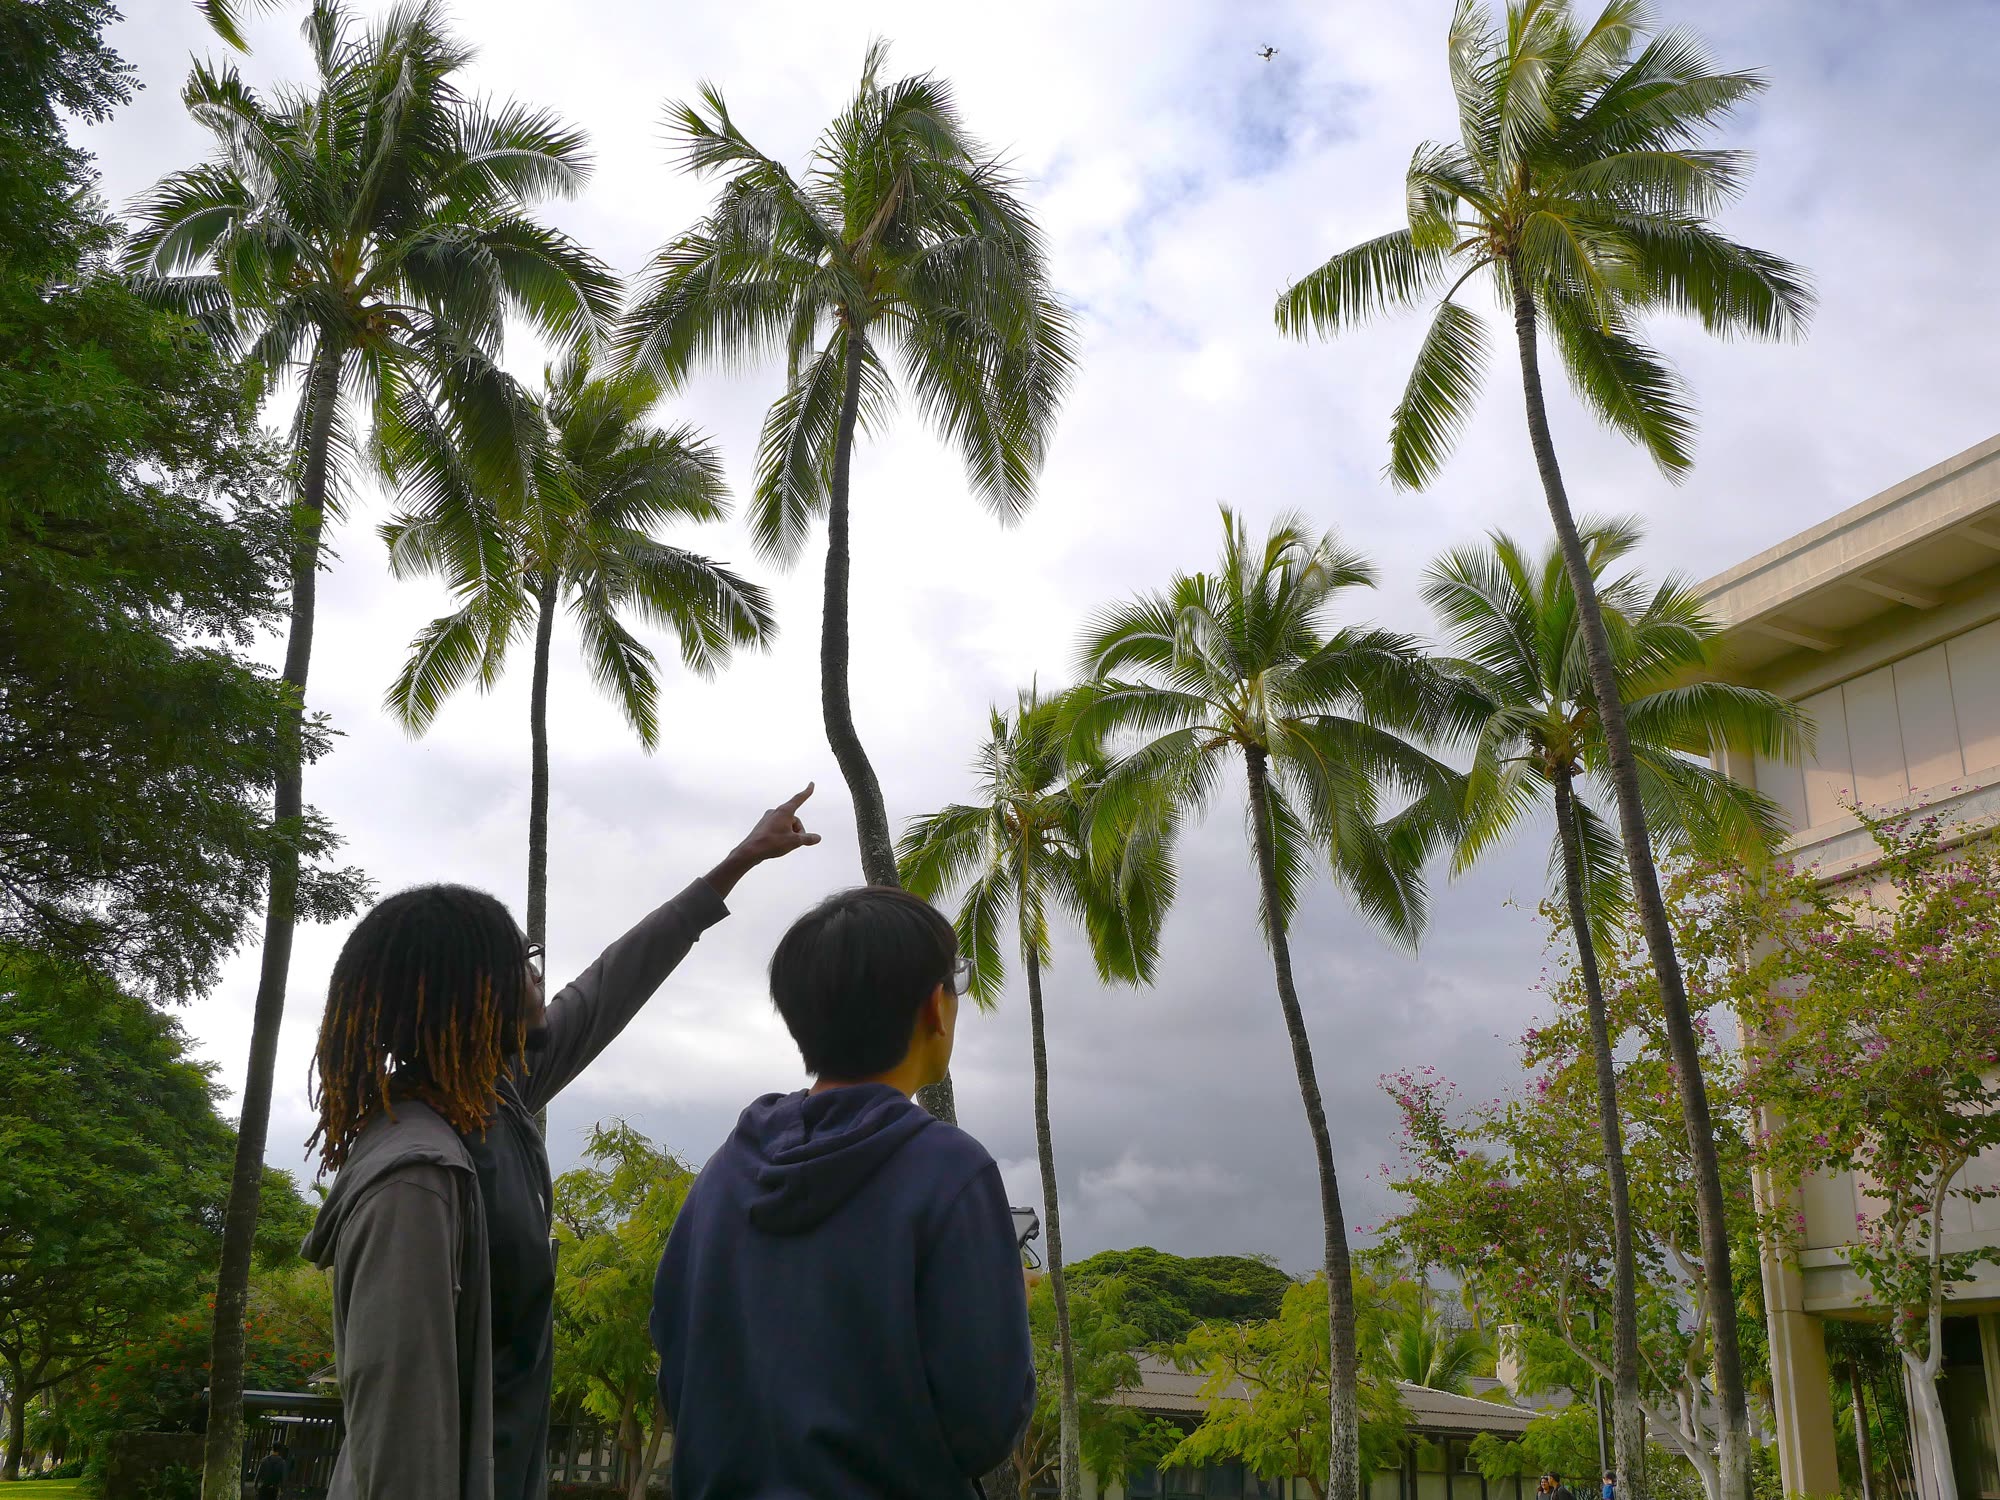
Robot development and fieldwork
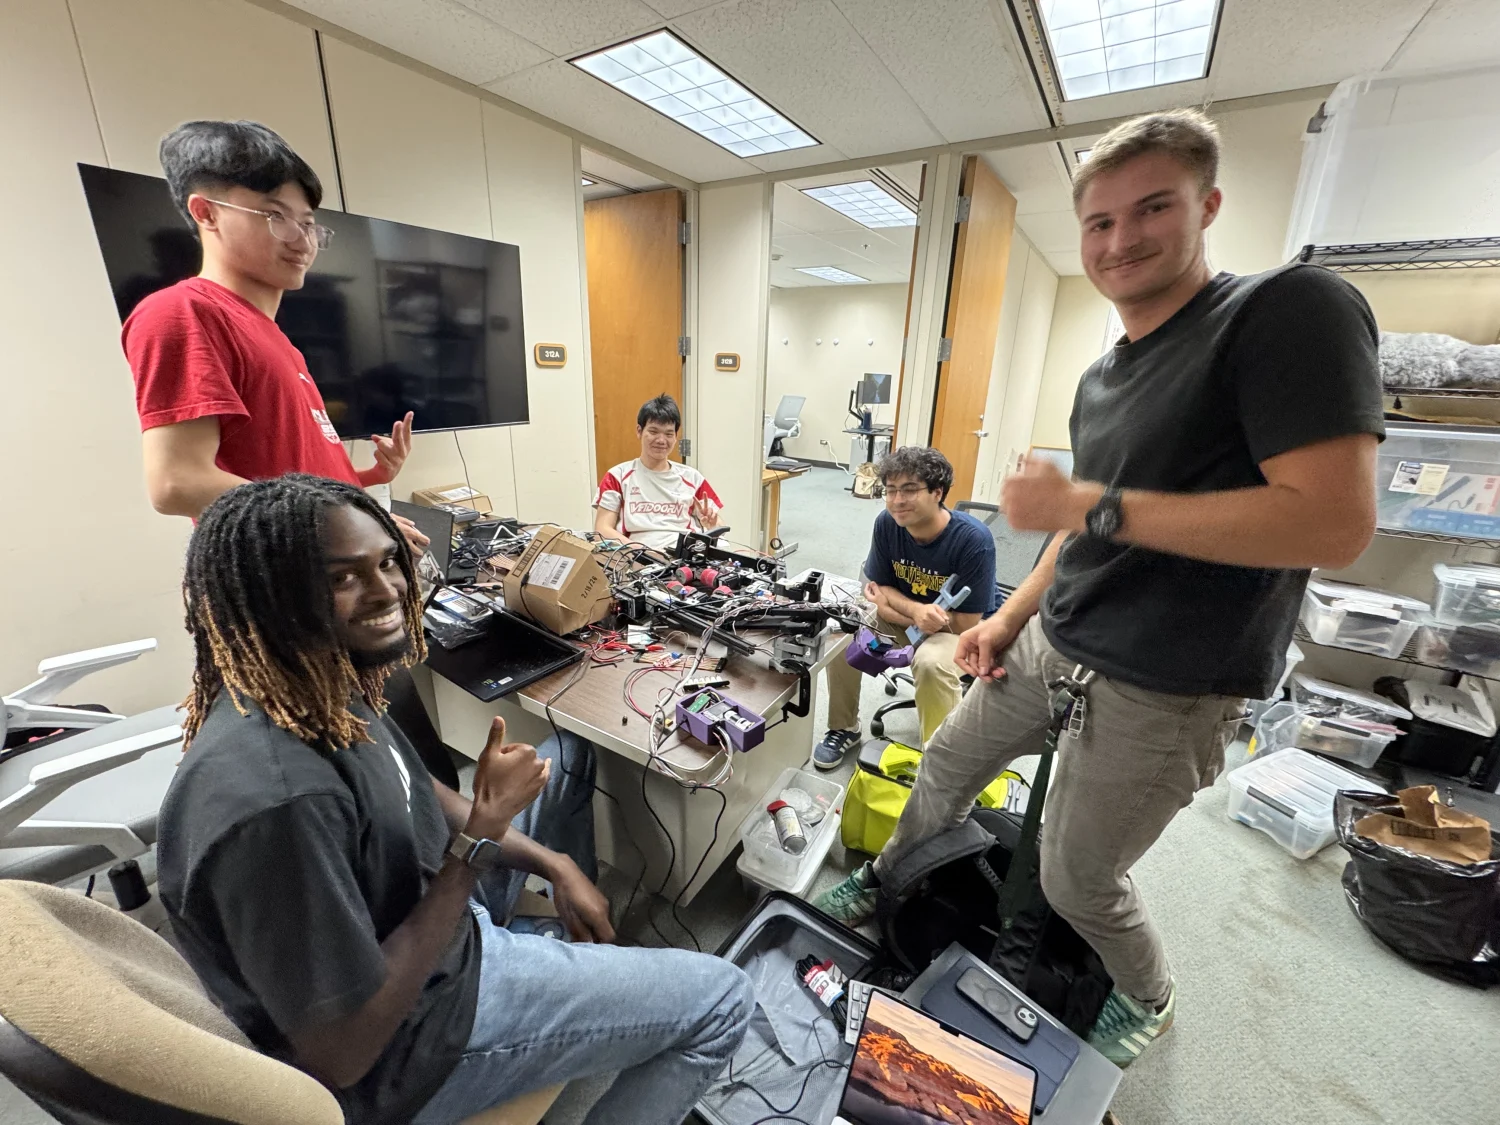
Project team
Perception system lead
Christian Moore
Advisors
Huaijin Chen · Daniel Jenkins · Ryan Kurasaki · Tianlu Wang · Daniel Drew · Xiaonan (Sean) Huang
University of Hawaiʻi at Mānoa team
Rona Lei Duldulao · Lucas Horsman · Wilson Huynh · Erik Bendickson · Christian Komo · Zadon Padello · Tyler Mak · Elijah Saloma · Kanta Saito · Ella Self · Andrew He · Lukas Moroz · Riki MacMillan · Alex Tokunaga · Owen Bramley
University of Michigan team
Nilay Choudhury · Xinqi Zhang · Yuchen You · Haobo Fang · Siyuan Zheng · Ronen Dujovny · Adrian Wang · Mingxuan He